
 Contact
 Comment faire ses achats

Livraison
Guide d'achat
 Anglais
 373 b
 Livraison à Autriche
Jusqu'à 30 jours pour les retours
Les clients ont également acheté


 /
 Livre de poche
 1.59
€




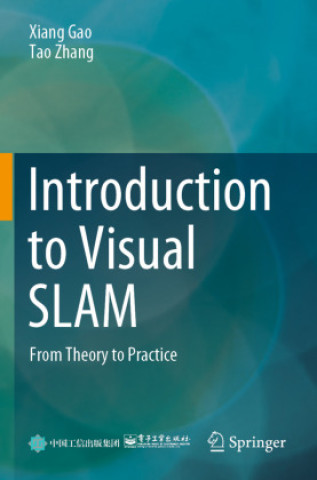
This book offers a systematic and comprehensive introduction to the visual simultaneous localization and mapping (vSLAM) technology, which is a fundamental and essential component for many applications in robotics, wearable devices, and autonomous driving vehicles. The book starts from very basic mathematic background knowledge such as 3D rigid body geometry, the pinhole camera projection model, and nonlinear optimization techniques, before introducing readers to traditional computer vision topics like feature matching, optical flow, and bundle adjustment. The book employs a light writing style, instead of the rigorous yet dry approach that is common in academic literature. In addition, it includes a wealth of executable source code with increasing difficulty to help readers understand and use the practical techniques. The book can be used as a textbook for senior undergraduate or graduate students, or as reference material for researchers and engineers in related areas.


À propos du livre
Anglais

Offrez ce livre dès aujourd'hui
C’est simple
1 Ajouter au panier et choisir l'option Livrer comme cadeau à la caisse. 2 Nous vous enverrons un bon d'achat 3 Le livre arrivera à l'adresse du destinataireCeci pourrait également vous intéresser



 /
Livre de poche
30.79
€
 /
Livre de poche
23.49
€


 /
Livre de poche
31.69
€

 /
Livre de poche
43.79
€


 /
Livre de poche
21.49
€

Bonjour ! Je suis Libroamiko, votre conseiller littéraire.
Comment puis-je vous aider ?